At a glance: Deploying a mobile robot in a GMP facility is a change to a validated state, and the questions that stall these projects are not payload or navigation accuracy. They are particle emission under motion, surface cleanability validated through a written procedure, whether the robot’s route is a controlled parameter, and whether its firmware can be frozen inside a change control system. This guide covers the four requirement groups, the documentation package to request at tender, and how DQ, IQ, OQ and PQ apply to a system that moves.
Deploying a mobile robot in a GMP manufacturing area is not a procurement exercise that happens to involve a quality department. It is a change to a validated facility, and the quality function is the decision-maker. The distinction matters because the questions that stall these projects are not the ones buyers prepare for: not payload or navigation accuracy, but whether the robot introduces a new particle source, whether its surfaces can be cleaned to the standard the area requires, whether its trajectory is a documented and controlled moving system, and whether the data it emits can be reconciled with an electronic records framework.
This guide sets out what a GMP-compliant mobile robot actually requires, organised by the four qualification stages a regulated facility already uses, with the data-room contents that decide how long each stage takes. It is written for the parties on both sides of these projects — quality and engineering staff in regulated facilities, and robot suppliers who want to understand why their standard platform does not pass.
Why a Cleanroom-Rated Robot Is Not Automatically a GMP Robot
The commercial market offers "cleanroom robots", which usually means a machine that has been tested for particle emission in a controlled environment. That is one requirement among many, and treating it as the qualifying standard is the most common reason a GMP deployment stalls late. The requirements divide into four groups with different owners inside the facility.
| Requirement group | What it covers | Facility owner | Evidence expected |
|---|---|---|---|
| Contamination control | Particle emission, surface cleanability, cleaning agent compatibility, no shedding materials, bioburden control where applicable | Quality / microbiology | Particle emission test report by ISO class, surface roughness where relevant, material compatibility statement, cleaning procedure validation |
| Computerised system | Data integrity, audit trail, access control, firmware change control, electronic records | QA / IT or CSV lead | GAMP-style classification, data integrity assessment against ALCOA+ criteria, audit trail demonstration, version control plan |
| Movement and routing | Mapped routes as controlled parameters, navigation changes, path deviation handling, blocking behaviour | Engineering / validation | Map and route version control, path deviation and obstruction response specification, test evidence for each intervention |
| Facility interfaces | Airlock and door passes, material transfer into classified zones, cleaning between zones, decontamination | Engineering / quality | Interface specification per boundary, zone transition procedure, cleaning frequency per grade |
Read the third group carefully, because it is the one with no equivalent in a general-purpose cleaning or delivery deployment. In a GMP facility the route a robot takes is not a runtime consideration to be optimised by navigation software; it is a documented and controlled parameter of the validated state. If the robot can autonomously re-route around an obstruction in a way that takes it through a different classified zone or past an open process, then the system has an undocumented degree of freedom, and the validation does not cover it. This is the requirement that most often forces a change to the navigation configuration rather than the hardware.
Particle Emission and Surface Cleanability
Contamination control is where the physical design of the platform is decided, and the design choices that pass are specific. A robot moving through a Grade B or C area continuously generates particles from four sources: wheel contact with the floor, motor and gearbox mechanism wear, the chassis moving a volume of air, and the surfaces it presents for cleaning.
| Particle source | Design measure that mitigates it | Evidence the facility will ask for |
|---|---|---|
| Wheel–floor contact and tyre wear | Non-shedding tyre compound, sealed wheel bearings, floor-grade compatibility statement | Material specification for the tyre compound; wear-rate data or a documented replacement interval |
| Motor and gearbox emission | Sealed drivetrain, no exposed lubricant, negative-pressure venting if required by the class | Particle emission rate measured during operation, not just at rest |
| Chassis movement displacing air | Low frontal area, smooth external surfaces, no upward-facing recesses | Particle counting around the moving unit under the facility's own environmental monitoring |
| Cleanability of the unit | Flat, continuous surfaces; sealed seams; IP-rated enclosure; wipe-down-compatible materials | Surface roughness data, cleaning agent compatibility, a written cleaning procedure the facility can validate |
Two practical points follow. The first is that particle emission must be measured while the robot is moving and executing its representative duty, because a stationary unit in a test chamber does not generate the wheel-wear or air-displacement contribution. A supplier report showing a static particle count should be treated as incomplete, and the facility's own environmental monitoring data during a trial run is more persuasive than a chamber certificate. The second is that cleanability is validated through the cleaning procedure the facility will actually use, not through a material property. A surface described as wipe-clean is not cleanable for GMP purposes until a written procedure has been validated with recovery data — which means the supplier's real deliverable is documentation sufficient for the facility to write that procedure, not a certificate.
Cleaning frequency as a controlled parameter
A robot in a classified area acquires a defined cleaning frequency and a defined agent, and both become part of the validated state. The frequency is typically set by the grade of the area and by the robot's own contamination profile — a unit that operates only in a Grade C corridor may be cleaned on a different schedule from one that enters a Grade B area. Once set, deviation from the frequency is a deviation that has to be documented, which has an operational consequence the deployment plan must absorb: somebody has to own the cleaning schedule, and it has to survive shift changes. In practice, facilities handle this by assigning the robot to a defined zone set with a single cleaning frequency, and by adding the robot to the existing cleaning log rather than maintaining a separate one.
Computerised System Requirements and Data Integrity
The robot's software stack is a computerised system under the facility's quality framework, and it requires classification and a data integrity assessment before deployment. The requirements below are the ones that appear in every assessment; the work is in deciding what each means for a mobile platform whose primary function is physical transport.
The firmware point deserves its own emphasis because it is where supplier assumptions and facility requirements are most directly opposed. Consumer and commercial fleet platforms are designed to update automatically, and that behaviour is a feature in a shopping mall. In a validated pharmaceutical facility the same behaviour is an unapproved change to a validated system, and the facility cannot accept it. A supplier who can freeze firmware, provide signed release notes for each version, and support a re-verification protocol for updates is a supplier whose platform can actually be deployed here. A supplier who cannot is one whose robot will be operated in a permanently out-of-date manual mode or not at all.
The interface between the robot and any facility system it writes to — a LIMS, an MES, a sample tracking application — is where the two requirement groups described above meet, and the specification work for that boundary is covered in fleet software integration.
Qualification: DQ, IQ, OQ, PQ for a Moving System
GMP facilities already operate a four-stage qualification sequence, and a mobile robot qualifies inside the existing framework rather than under a separate scheme. The work differs from a static equipment qualification in the degree to which the "as installed" and "as operated" states depend on a digital map and on behavioural configurability.
| Stage | Applied to a mobile robot | Typical duration | What makes it run long |
|---|---|---|---|
| DQ — Design Qualification | Documented requirement against the platform: particle emission by class, surface finish, cleaning agent compatibility, data integrity features, navigation constraints, interfaces | 2–6 weeks | Requirements written after the platform was chosen, forcing retrofitted justification |
| IQ — Installation Qualification | Verified installation: unit identity and serial, software and firmware versions, map and route versions loaded, dock and charge point installation, network configuration, account and permission setup | 1–3 weeks | Map and route versions not under version control at the supplier's end |
| OQ — Operational Qualification | Documented test of the system across its intended operating range: every route, every zone transition, obstruction and deviation response, exception handling, audit trail capture, access control, data write to destination systems | 3–8 weeks | Test cases that were never defined because behaviour was assumed rather than specified |
| PQ — Performance Qualification | Demonstration that the system performs consistently under production conditions over an extended period: continuous runs, environmental monitoring data, cleaning cycle compliance, service intervals | 4–12 weeks | Environmental monitoring excursions during the trial that require investigation |
The stage where these projects most often lose months is OQ, and the cause is almost always the same: the deviation and obstruction response behaviour was never specified, so there are no test cases for it, so the testing cannot complete. A supplier who provides a written behavioural specification — what the robot does when a route is blocked, whether it re-routes autonomously, how far it may deviate, whether it stops and alerts, what it does at a zone boundary if the door is not open — removes most of that risk before qualification begins. This specification is the single most valuable document a supplier can bring to a GMP project, more so than a particle certificate.
PQ is where the operational reality of a GMP environment becomes visible. The extended run is not primarily a test of the robot; it is a test of whether the facility's own processes accommodate it. Environmental monitoring during the trial period has to show no excursion attributable to the unit. Cleaning logs have to show the robot cleaned on the defined frequency without a missed entry during shift handovers. Any deviation found in PQ has to be investigated through the facility's normal deviation system, which means the trial length is partly a function of how quickly those investigations close.
Material Transfer and Zone Transitions
A mobile robot in a GMP facility usually crosses a boundary during its duty, and each boundary has its own qualification requirement. The physics of a pass-through is where a design that performs well in corridors meets its hardest constraint.
| Boundary | Requirement | Design implication |
|---|---|---|
| Grade C corridor to Grade B area | Grade-appropriate cleaning of the unit before entry; documented transition procedure | The unit must be cleanable to Grade B standard and the procedure must be validated; some facilities require a wipe-down station at the airlock |
| Airlock with interlocked doors | Robot must integrate with the interlock without defeating it; no route through an open airlock while the opposite door is open | Requires a facility interface to the airlock control system, not just door-opening capability |
| Changing room or personnel airlock | Often not passable by a robot at all | Route design must avoid personnel and material airlocks where possible; this may exclude a route the project assumed was available |
| Return to non-classified area | Documented cleaning on exit; the unit may carry classified-area contamination outward | Cleaning schedule must cover the exit direction, not only the entry direction |
The airlock point is one where a supplier's standard capability and a facility's requirement frequently mismatch. Many platforms can open a door via a signal, which is useful in a hospital corridor and insufficient in a GMP airlock, where the interlock logic itself has to be respected and the robot's presence has to be visible to the facility's control system. Resolving this is an engineering project, and it should be identified in DQ rather than discovered at IQ. The equivalent interface question for materials moving between zones in a non-pharmaceutical but contamination-controlled setting is treated in laboratory and cleanroom deployments.
The Data Room: What to Ask For Before the Project Starts
The speed of a GMP deployment is largely determined by the completeness of the supplier documentation package, and the package should be requested at tender rather than after selection. The items below are the ones that, if missing, will each cost weeks.
- Particle emission data measured under motion, by ISO class, with the duty cycle and sampling method stated.
- Material and surface documentation: roughness data for contact and non-contact surfaces, a cleaning agent compatibility statement listing agents tested, and material declarations for all exposed parts.
- A behavioural specification for navigation: route deviation limits, obstruction response, zone-boundary behaviour, human-encounter behaviour, and what happens on loss of network or loss of map.
- Data integrity documentation: audit trail contents and retention, account model and permission matrix, export format, and how records are made available for inspection.
- Firmware and configuration control: whether automatic updates can be disabled, release notes per version, and a re-verification protocol for updates.
- Interface specifications for airlock control, door signals and destination systems, with supported protocols named.
- Service and calibration procedures with intervals, and a statement of which procedures can be performed in a classified area and which require the unit to be removed.
- Cleaning procedure input: agent compatibility, contact time tolerance, and which surfaces may not be wetted or sprayed.
The service-procedure item is easy to overlook and operationally important. A robot requiring routine maintenance in place will need a documented procedure and a work permit for the classified area, and the maintenance activity itself becomes a potential contamination event. A robot whose routine service can be performed outside the classified area, with only cleaning required inside, is substantially easier to operate. That is a design property, and it is worth weighting in selection.
Sequencing a First Deployment
The deployments that complete on schedule share a common sequence, and it is not the intuitive one. The order that works is: define the routes and zone transitions first, then obtain the behavioural and contamination documentation against those routes, then write the DQ, then select the platform. Selecting a platform first and then constructing the requirement around it reliably produces DQ documents that are justifications rather than requirements, and validation functions recognise the difference.
A practical first project also keeps the scope narrow enough to qualify. One robot, one route, one zone transition, one duty — sample transport from a production area to a QC laboratory, for example, or transfer of components from a staging area into a dispensing room. A narrow scope that completes qualification in a quarter establishes the procedure, the documentation set and the internal ownership of the robot, and every subsequent route on the same platform inherits that work. A first project that attempts the whole facility validates nothing and consumes a year.
The GMP framework also has an advantage that deployments outside it lack: the requirement is written down before the project begins, and the evidence that closes each stage is defined in advance. A supplier who can deliver against a written requirement is the right partner, and the asking of the requirement is how the facility finds out which supplier that is.
For the wider regulatory context around service robot deployment — machinery safety, transport of lithium cells, and the standards a platform is expected to meet outside a GMP framework — see safety and compliance standards. For the analytical layer that supports the ongoing operational case once the robot is qualified and running, see service robot KPI benchmarks; for the broader treatment of robot data handling and privacy obligations outside a GMP framework, see security, privacy and robot data.
How AOMAN Works on Regulated Deployments
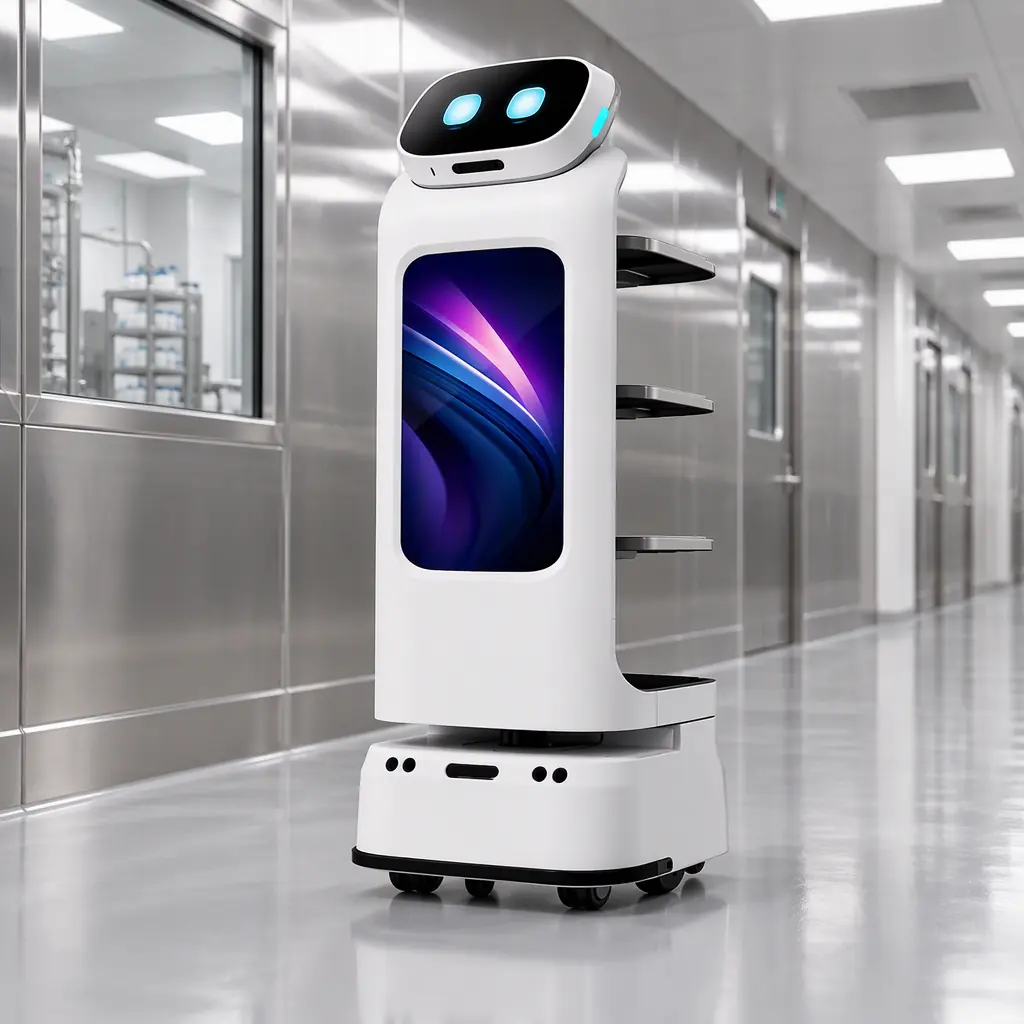
AOMAN FUTURE builds the D1 delivery robot, C1 large-format cleaning robot, C2 Pro compact cleaner and G1 reception robot in Shenzhen. For regulated facilities we work from the route and zone definition rather than from a catalogue configuration: the D1 platform is the one usually appropriate for in-facility material transfer, and its documentation package — surface and material data, cleaning-agent compatibility, navigation behaviour specification with route deviation limits and obstruction response, audit trail contents, and firmware release control with automatic updates disabled — is prepared so that DQ can be written against it rather than retrofitted to it.
We will be direct about where a standard platform is not the right answer. Airlock interlocking, negative-pressure venting and Grade B entry are project-specific engineering, not catalogue features, and they are best addressed in the design stage with the facility's engineering and quality teams. If your scope involves a classified area, send us the route, the zone classes and the duty and we will tell you what the platform can carry and what has to be engineered around it. The wider engineering context is on the technology page, and the production and quality framework is described at the Shenzhen facility.